I2C Simulations
These five MicroSims go with Appendix A: The I2C Bus. Do them in order. Each one builds on the one before it.
What Each MicroSim Shows
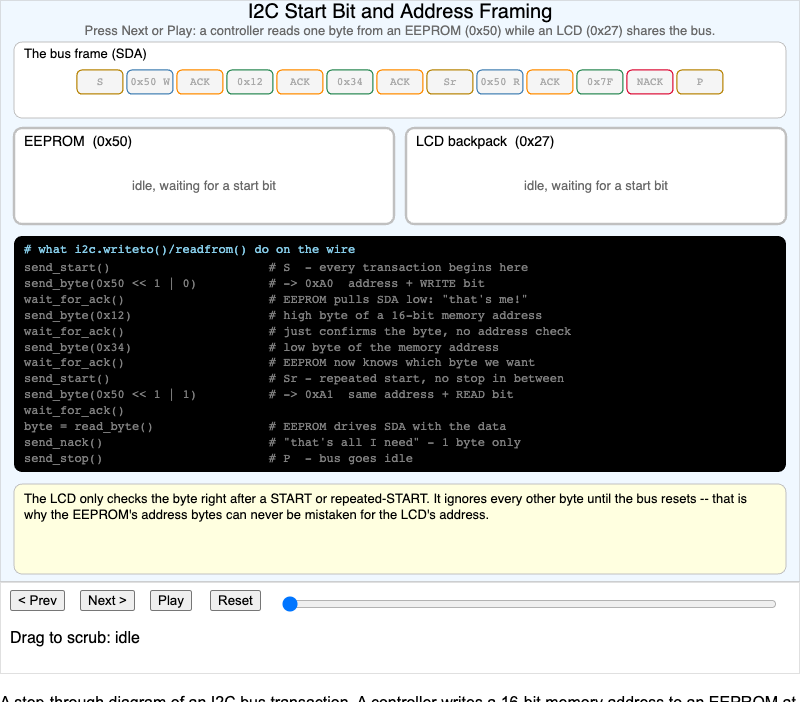
- I2C Start Bit and Address Framing. Step through a real transaction byte by byte: a controller writes a 16-bit memory address to an EEPROM, then reads a byte back, while an LCD shares the same bus. See exactly when a device checks the bus for its own address, and why it can't be confused by another device's data bytes.
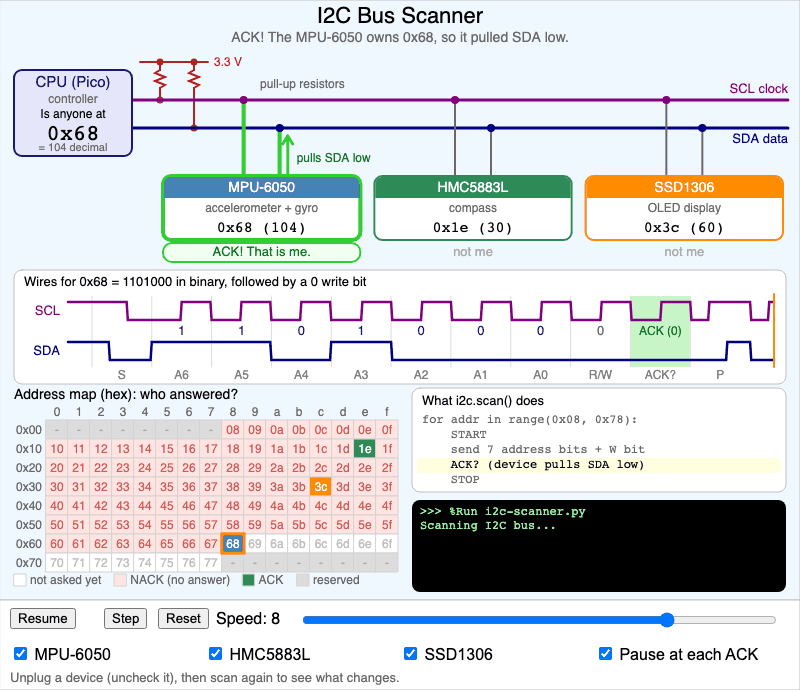
- I2C Bus Scanner. The Pico asks every address, "is anyone there?" Chips answer with an ACK. Unplug a chip and scan again.
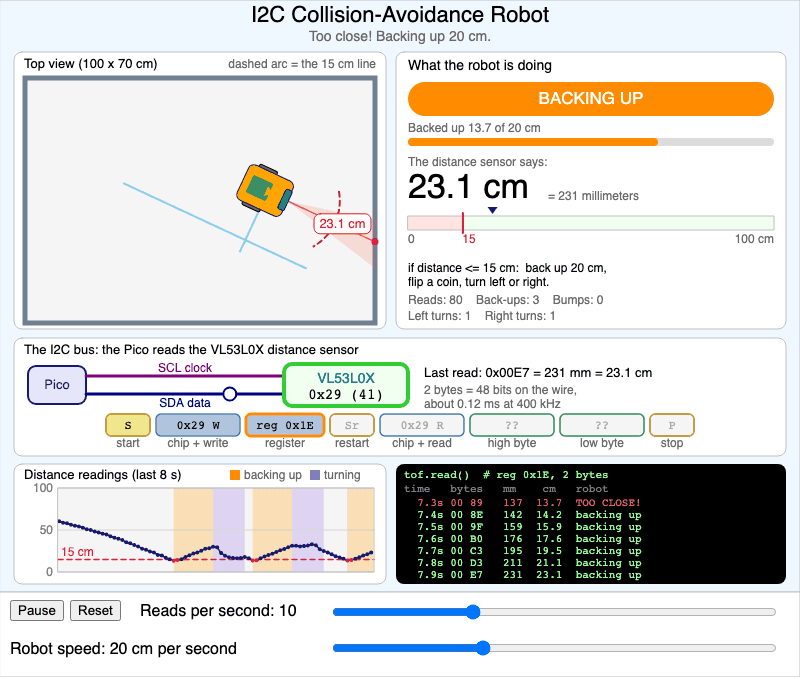
- I2C Collision-Avoidance Robot. One distance sensor on the I2C bus steers a robot. Within 15 cm of a wall, the robot backs up 20 cm and flips a coin to turn left or right. Slow the reads down and watch it bump.
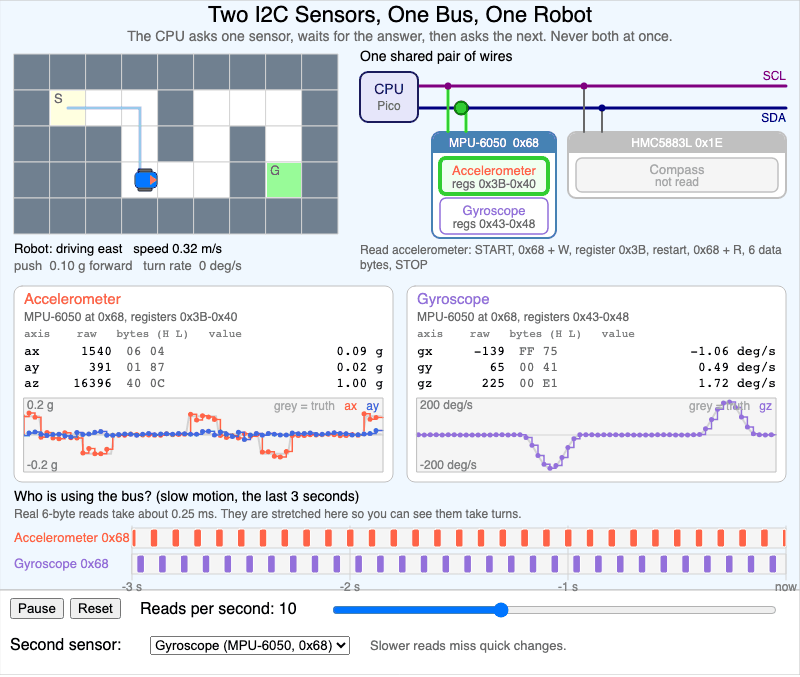
- I2C Two Sensors in a Maze. A robot drives a maze. The Pico reads an accelerometer, then a gyroscope or a compass, taking turns on one bus.
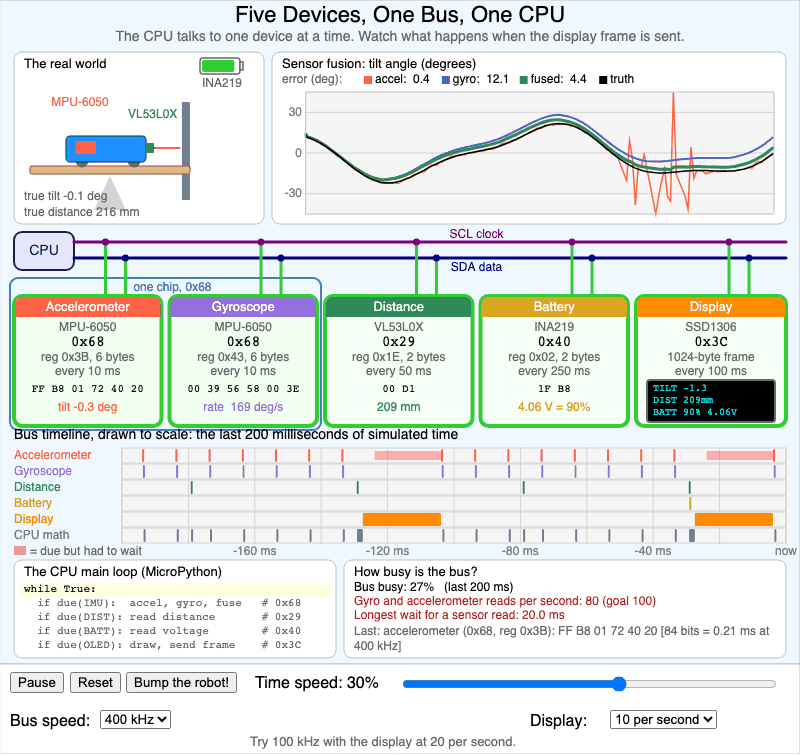
- I2C Five-Device Sensor Fusion. Five devices share one bus. See a display picture block the sensors. Then fuse the accelerometer and the gyroscope into one clean angle.