About This Book
Controlling a Robot Arm is an interactive intelligent textbook on sourcing parts, building, and programming low-cost robot arms. It uses two open-source arms as hands-on case studies: the $350 3D-printed SO-ARM100 (and its successor, the SO-ARM101) and the $1,200 Seeed Studio reBot-DevArm.
This book is both a book on robot arms and a hands-on guide to learn how to use Python programming to move a real robot. Every chapter turns an idea into code that reads a sensor, moves a joint, or makes a decision, and then shows the result on a physical arm.
Welcome, Builder!
 I'm Servo, your guide through this book. By the end, you'll have a robot arm you built yourself, moving under Python code you wrote. Let's move it!
Why Teach Robotics Now
Robots are no longer confined to a few car factories. The number of robots at work is growing every year, the price of building one has collapsed, and the AI that guides them is improving fast. The students who learn how a robot senses, plans, and acts today will be the engineers who decide what these machines do tomorrow.
Worldwide:
- Factories worldwide installed more than 600,000 new industrial robots in 2025, an 11% jump, and the global stock of working industrial robots reached a record 5 million1
- The average factory had 162 robots for every 10,000 employees in 2023, more than double the 74 measured seven years earlier2
- Goldman Sachs Research projects that the market for humanoid robots could reach $38 billion by 20353
In the United States:
- American factories had 285 robots per 10,000 employees in 2022. South Korea, the world leader, had 1,012, more than three times as many4
- Deloitte and The Manufacturing Institute estimate that U.S. manufacturing could need as many as 3.8 million new employees between 2024 and 2033, and that 1.9 million of those jobs could go unfilled if skills and applicant gaps are not addressed5
- Only 46% of eighth graders performed at or above the Proficient level on the 2018 National Assessment of Educational Progress in technology and engineering literacy6
These numbers describe a gap. Robots are spreading quickly, the jobs around them are going unfilled, and fewer than half of students are ready for the technology that will shape their working lives. Waiting until college to meet a robot is waiting too long. A twelve-year-old who can build and program an arm for a few hundred dollars gets a head start that earlier generations could only get in a university lab.
Why the Timing Is Different
Three changes make this the right moment to teach hands-on robotics:
- Cost. A complete, open-source six-joint arm now costs hundreds of dollars, not tens of thousands. A classroom can afford a robot for every team.
- Software. Open-source libraries and Python let a student control real hardware with short programs. Chapters 10 through 14 build exactly that skill.
- AI. Language models and learned policies can now plan and control physical machines. That makes it urgent for students to understand safety, testing, and limits, the topics of Chapters 15 through 17, before AI-driven robots are everywhere.
What Makes This Book Different
This book is built on a learning graph of 537 interconnected concepts organized into 15 taxonomy categories across 19 chapters, so ideas are introduced only after their prerequisites. It includes interactive MicroSims, browser-based simulations that let you change a voltage, a joint angle, or a wire length and watch what happens. Every program runs against a software "fake arm" before it touches hardware. The entire book is open source and free, with no paywalls and no access codes.
Who This Book Is For
- Students aged 12 and up who have finished a first Python course and want a project that uses Python to control a physical machine.
- Makers, hobbyists, and self-taught roboticists who can write basic Python and want to build and program their first arm.
- Teachers, makerspace leaders, and club mentors who need a low-cost lab platform and a parts list they can order from.
- Software developers and AI practitioners who want to give an AI agent a physical body and need to learn the hardware side.
The full list of topics and learning outcomes is in the Course Description.
How to Use This Book
- Read chapters in order. Concepts are introduced in dependency order, so prerequisites always come first.
- Try the MicroSims as you meet them. They are the fastest way to build intuition for a new concept.
- Simulate first, then power on. Every program runs against a software "fake arm" before it touches hardware.
- Use the search bar (top right) to jump to a specific term.
- Check the Learning Graph when you want to see how a concept fits into the larger picture.
Why I Wrote This Book
I have been teaching STEM robotics since 2014. In that time I have watched the cost of a capable robot arm fall to a few hundred dollars. A student with a 3D printer, a dozen servos, and some Python can now build a machine that would have been a research-lab project not long ago.
That change matters beyond the classroom. I believe every engineer, whatever their specialty, should understand how robots work, because robots are about to become a much bigger part of the world. The people who understand how a robot senses, plans, and acts will help decide where those machines go. Everyone else will just live with the results.
Why World Models
I am a big fan of world models: learned systems that give a machine an internal picture of how the world behaves, so it can predict what will happen before it acts. A robot with a good world model can ask "what happens if I move my gripper here?" and imagine the answer instead of finding out the hard way. This is where I think robotics and AI are heading, and it is why the later chapters of this book connect arms to cameras, simulation, and AI agents.
Investors are betting heavily on this idea:
- In March 2026, Yann LeCun's new company, Advanced Machine Intelligence (AMI), raised $1.03 billion in seed funding at a valuation of about $3.5 billion to build world models based on his JEPA architecture7
- On September 28, 2026, AMD agreed to acquire World Labs, the company founded by Fei-Fei Li, in an all-stock deal valued at about $8.2 billion. The deal is expected to close by the end of 2026, and Li will become AMD's chief scientist8
Funding is not proof that the technology works. But when a chip company pays billions to shape its future processors around world models, it signals that the people who fund robots and AI expect these models to matter.
Understanding the pieces under a world model starts with the basics in this book: joint angles, kinematics, sensors, and feedback loops. You can't judge a robot's prediction about the world until you know what the robot can measure.
The Laundry Challenge
I also have a selfish motive for this book: I hate doing laundry.
Folding clothes is a surprisingly hard problem for a robot. Shirts and towels are floppy, they change shape every time you touch them, and no two piles look alike. That makes laundry a wonderful test of everything this book teaches: perception, grasping, planning, and learning from demonstration.
A Great Capstone Project
 Folding a shirt combines nearly every skill in this book: seeing the cloth, choosing where to grab, moving smoothly, and learning from a human demonstration. Could a low-cost arm like the ones you'll build do it?
So here is my open challenge to every student who reads this book:
Build a low-cost robot that does my laundry.
If you build one that works, even one that only folds a pair of socks, please contact me. I would love to see it, and I will happily be your first customer.
About the Author
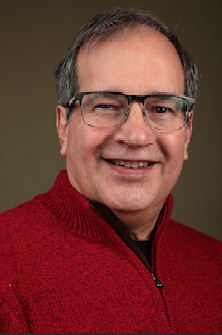
Dan McCreary is a semi-retired AI researcher, solution architect, and educator who has spent more than three decades helping Fortune 100 organizations reason over massive datasets. At Optum he founded the Generative AI Center of Excellence and led the team that built one of the world's largest healthcare knowledge graphs, spanning over 25 billion vertices, to unify member, provider, and patient insights. That background in knowledge representation and systems thinking underpins the learning graphs and intelligent-textbook workflows used throughout this book.
He is the co-author of Making Sense of NoSQL (Manning Publications), the founding chair of the NoSQL Now! conference, and a frequent keynote speaker on semantic search, ontology strategy, and AI hardware. You can visit the Intelligent Textbooks Case Studies to see over 87 textbooks that Dan has created or co-created with other authors.
From Chip Design to Classroom Robots
Dan's career started close to the hardware. He began as a member of technical staff at AT&T Bell Labs, designing VLSI CMOS integrated circuits, and then managed a team of 14 software engineers at ETA Systems, a supercomputer company. At NeXT Computer he worked with Steve Jobs as a systems engineer, developing sales and training materials. He later founded and grew a software services company, served as CIO of an accounting firm, and has worked as an independent technology strategist in metadata, data warehousing, and semantic technologies. Along the way he wrote over 200 wikibook articles on XML technologies such as XQuery and XSLT. Teaching technical material to others has been a constant thread in all of these roles.
Teaching and Mentoring
Dan has mentored students as a STEM volunteer since 2014, teaching robotics and microcontroller programming in CoderDojo-style coding clubs. Those clubs ranged from three students around one table to 150 students supported by 50 mentors. The observations from those years are the raw material for this book.
Selected Credentials
- B.A. in Physics and Computer Science from Carleton College
- M.S.E.E. from the University of Minnesota
- MBA coursework at the University of St. Thomas
- Patent holder in semantic search and ontology management techniques
- Advocate for large-scale Enterprise Knowledge Graph adoption across healthcare and education
- Long-time promoter of accessible, low-cost AI-powered learning experiences
You can connect with Dan on LinkedIn or through the Contact page.
How to Cite This Book
If you reference this textbook in academic work, curriculum proposals, lesson plans, grant applications, or other publications, please use one of the following citation formats.
APA (7th edition)
McCreary, D. (2026). Controlling a Robot Arm. https://dmccreary.github.io/robot-arm/
Chicago (17th edition)
McCreary, Dan. 2026. Controlling a Robot Arm. https://dmccreary.github.io/robot-arm/.
MLA (9th edition)
McCreary, Dan. Controlling a Robot Arm. 2026, dmccreary.github.io/robot-arm/.
BibTeX
@book{mccreary2026robotarm,
  title     = {Controlling a Robot Arm},
  author    = {McCreary, Dan},
  year      = {2026},
  url       = {https://dmccreary.github.io/robot-arm/},
  note      = {Interactive intelligent textbook}
}
To cite a specific chapter, append the chapter number and title. For example:
McCreary, D. (2026). Chapter 1: Setting Up Python for Robotics. In Controlling a Robot Arm. https://dmccreary.github.io/robot-arm/chapters/01-python-setup-for-robotics/
To cite a MicroSim, use its lesson page, for example:
McCreary, D. (2026). Two-Link Workspace Explorer [Interactive simulation]. In Controlling a Robot Arm. https://dmccreary.github.io/robot-arm/sims/two-link-workspace-explorer/
License and Source
This work is released under the Creative Commons Attribution-NonCommercial-ShareAlike 4.0 International License (CC BY-NC-SA 4.0). You are free to share and adapt the material for non-commercial purposes as long as you give appropriate credit and share your adaptations under the same license.
The source, including every chapter and MicroSim, is on GitHub. Corrections and contributions are welcome.
References
-
International Federation of Robotics. (2026, September 24). Five Million Robots Now Operate in Factories Globally. https://ifr.org/ifr-press-releases/five-million-robots-now-operate-in-factories-globally ↩
-
International Federation of Robotics. (2024, November). Global Robot Density in Factories Doubled in Seven Years. https://ifr.org/ifr-press-releases/global-robot-density-in-factories-doubled-in-seven-years ↩
-
Goldman Sachs Research. (2024, February 27). The Global Market for Robots Could Reach $38 Billion by 2035. https://www.goldmansachs.com/insights/articles/the-global-market-for-robots-could-reach-38-billion-by-2035 ↩
-
International Federation of Robotics. (2024, January 10). Global Robotics Race: Korea, Singapore and Germany in the Lead. https://ifr.org/ifr-press-releases/news/global-robotics-race-korea-singapore-and-germany-in-the-lead ↩
-
Deloitte and The Manufacturing Institute. (2024, April). Taking Charge: Manufacturers Support Growth with Active Workforce Strategies. https://themanufacturinginstitute.org/manufacturers-need-as-many-as-3-8-million-new-employees-by-2033/ ↩
-
National Center for Education Statistics. (2019). The Nation's Report Card: 2018 Technology and Engineering Literacy (TEL) Highlights. https://nationsreportcard.gov/tel_2018_highlights ↩
-
Silicon Republic. (2026, March). Yann LeCun's AI Start-up AMI Raises $1.03bn in Seed Funding. https://www.siliconrepublic.com/start-ups/yann-lecun-ai-start-up-ami-raises-seed-funding-world-model ↩
-
AMD. (2026, September 28). AMD to Acquire World Labs to Advance the Future of AI Compute. https://newsroom.amd.com/news/amd-acquire-world-labs/ ↩